Class for CTR Electronics' CANdi™ branded device, a device that integrates digital signals into the existing CAN bus network. More...
#include <ctre/phoenix6/core/CoreCANdi.hpp>
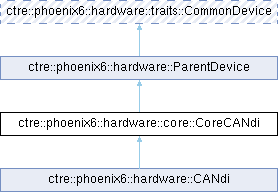
Public Types | |
| using | Configuration = configs::CANdiConfiguration |
| The configuration class for this device. | |
Public Member Functions | |
| CoreCANdi (int deviceId, CANBus canbus={}) | |
| Constructs a new CANdi object. | |
| CoreCANdi (int deviceId, std::string canbus) | |
| Constructs a new CANdi object. | |
| configs::CANdiConfigurator & | GetConfigurator () |
| Gets the configurator for this CANdi. | |
| configs::CANdiConfigurator const & | GetConfigurator () const |
| Gets the configurator for this CANdi. | |
| sim::CANdiSimState & | GetSimState () |
| Get the simulation state for this device. | |
| StatusSignal< int > & | GetVersionMajor (bool refresh=true) |
| App Major Version number. | |
| StatusSignal< int > & | GetVersionMinor (bool refresh=true) |
| App Minor Version number. | |
| StatusSignal< int > & | GetVersionBugfix (bool refresh=true) |
| App Bugfix Version number. | |
| StatusSignal< int > & | GetVersionBuild (bool refresh=true) |
| App Build Version number. | |
| StatusSignal< int > & | GetVersion (bool refresh=true) |
| Full Version of firmware in device. | |
| StatusSignal< int > & | GetFaultField (bool refresh=true) |
| Integer representing all fault flags reported by the device. | |
| StatusSignal< int > & | GetStickyFaultField (bool refresh=true) |
| Integer representing all (persistent) sticky fault flags reported by the device. | |
| StatusSignal< bool > & | GetIsProLicensed (bool refresh=true) |
| Whether the device is Phoenix Pro licensed. | |
| StatusSignal< signals::S1StateValue > & | GetS1State (bool refresh=true) |
| State of the Signal 1 input (S1IN). | |
| StatusSignal< signals::S2StateValue > & | GetS2State (bool refresh=true) |
| State of the Signal 2 input (S2IN). | |
| StatusSignal< units::angle::turn_t > & | GetQuadraturePosition (bool refresh=true) |
| Position from a quadrature encoder sensor connected to both the S1IN and S2IN inputs. | |
| StatusSignal< units::time::microsecond_t > & | GetPWM1RiseToRise (bool refresh=true) |
| Measured rise to rise time of the PWM signal at the S1 input of the CTR Electronics' CANdi™. | |
| StatusSignal< units::angle::turn_t > & | GetPWM1Position (bool refresh=true) |
| Measured position of the PWM sensor at the S1 input of the CTR Electronics' CANdi™. | |
| StatusSignal< units::angular_velocity::turns_per_second_t > & | GetPWM1Velocity (bool refresh=true) |
| Measured velocity of the PWM sensor at the S1 input of the CTR Electronics' CANdi™. | |
| StatusSignal< units::time::microsecond_t > & | GetPWM2RiseToRise (bool refresh=true) |
| Measured rise to rise time of the PWM signal at the S2 input of the CTR Electronics' CANdi™. | |
| StatusSignal< units::angle::turn_t > & | GetPWM2Position (bool refresh=true) |
| Measured position of the PWM sensor at the S2 input of the CTR Electronics' CANdi™. | |
| StatusSignal< bool > & | GetOvercurrent (bool refresh=true) |
| True when the CANdi™ is in overcurrent protection mode. | |
| StatusSignal< units::voltage::volt_t > & | GetSupplyVoltage (bool refresh=true) |
| Measured supply voltage to the CANdi™. | |
| StatusSignal< units::current::ampere_t > & | GetOutputCurrent (bool refresh=true) |
| Measured output current. | |
| StatusSignal< units::angular_velocity::turns_per_second_t > & | GetPWM2Velocity (bool refresh=true) |
| Measured velocity of the PWM sensor at the S2 input of the CTR Electronics' CANdi™. | |
| StatusSignal< units::angular_velocity::turns_per_second_t > & | GetQuadratureVelocity (bool refresh=true) |
| Velocity from a quadrature encoder sensor connected to both the S1IN and S2IN inputs. | |
| StatusSignal< bool > & | GetS1Closed (bool refresh=true) |
| True if the Signal 1 input (S1IN) matches the configured S1 Closed State. | |
| StatusSignal< bool > & | GetS2Closed (bool refresh=true) |
| True if the Signal 2 input (S2IN) matches the configured S2 Closed State. | |
| StatusSignal< bool > & | GetFault_Hardware (bool refresh=true) |
| Hardware fault occurred. | |
| StatusSignal< bool > & | GetStickyFault_Hardware (bool refresh=true) |
| Hardware fault occurred. | |
| StatusSignal< bool > & | GetFault_Undervoltage (bool refresh=true) |
| Device supply voltage dropped to near brownout levels. | |
| StatusSignal< bool > & | GetStickyFault_Undervoltage (bool refresh=true) |
| Device supply voltage dropped to near brownout levels. | |
| StatusSignal< bool > & | GetFault_BootDuringEnable (bool refresh=true) |
| Device boot while detecting the enable signal. | |
| StatusSignal< bool > & | GetStickyFault_BootDuringEnable (bool refresh=true) |
| Device boot while detecting the enable signal. | |
| StatusSignal< bool > & | GetFault_UnlicensedFeatureInUse (bool refresh=true) |
| An unlicensed feature is in use, device may not behave as expected. | |
| StatusSignal< bool > & | GetStickyFault_UnlicensedFeatureInUse (bool refresh=true) |
| An unlicensed feature is in use, device may not behave as expected. | |
| StatusSignal< bool > & | GetFault_5V (bool refresh=true) |
| The CTR Electronics' CANdi™ branded device has detected a 5V fault. | |
| StatusSignal< bool > & | GetStickyFault_5V (bool refresh=true) |
| The CTR Electronics' CANdi™ branded device has detected a 5V fault. | |
| ctre::phoenix::StatusCode | SetQuadraturePosition (units::angle::turn_t newValue, units::time::second_t timeoutSeconds) |
| Sets the position of the quadrature input. | |
| ctre::phoenix::StatusCode | SetQuadraturePosition (units::angle::turn_t newValue) |
| Sets the position of the quadrature input. | |
| ctre::phoenix::StatusCode | ClearStickyFaults (units::time::second_t timeoutSeconds) |
| Clear the sticky faults in the device. | |
| ctre::phoenix::StatusCode | ClearStickyFaults () |
| Clear the sticky faults in the device. | |
| ctre::phoenix::StatusCode | ClearStickyFault_Hardware (units::time::second_t timeoutSeconds) |
| Clear sticky fault: Hardware fault occurred. | |
| ctre::phoenix::StatusCode | ClearStickyFault_Hardware () |
| Clear sticky fault: Hardware fault occurred. | |
| ctre::phoenix::StatusCode | ClearStickyFault_Undervoltage (units::time::second_t timeoutSeconds) |
| Clear sticky fault: Device supply voltage dropped to near brownout levels. | |
| ctre::phoenix::StatusCode | ClearStickyFault_Undervoltage () |
| Clear sticky fault: Device supply voltage dropped to near brownout levels. | |
| ctre::phoenix::StatusCode | ClearStickyFault_BootDuringEnable (units::time::second_t timeoutSeconds) |
| Clear sticky fault: Device boot while detecting the enable signal. | |
| ctre::phoenix::StatusCode | ClearStickyFault_BootDuringEnable () |
| Clear sticky fault: Device boot while detecting the enable signal. | |
| ctre::phoenix::StatusCode | ClearStickyFault_UnlicensedFeatureInUse (units::time::second_t timeoutSeconds) |
| Clear sticky fault: An unlicensed feature is in use, device may not behave as expected. | |
| ctre::phoenix::StatusCode | ClearStickyFault_UnlicensedFeatureInUse () |
| Clear sticky fault: An unlicensed feature is in use, device may not behave as expected. | |
| ctre::phoenix::StatusCode | ClearStickyFault_5V (units::time::second_t timeoutSeconds) |
| Clear sticky fault: The CTR Electronics' CANdi™ branded device has detected a 5V fault. | |
| ctre::phoenix::StatusCode | ClearStickyFault_5V () |
| Clear sticky fault: The CTR Electronics' CANdi™ branded device has detected a 5V fault. | |
 Public Member Functions inherited from ctre::phoenix6::hardware::ParentDevice | |
| ParentDevice (int deviceID, std::string model, CANBus canbus) | |
| virtual | ~ParentDevice ()=0 |
| ParentDevice (ParentDevice const &)=delete | |
| ParentDevice & | operator= (ParentDevice const &)=delete |
| int | GetDeviceID () const final |
| CANBus | GetNetwork () const final |
| uint64_t | GetDeviceHash () const final |
| Gets a number unique for this device's hardware type and ID. | |
| std::shared_ptr< controls::ControlRequest const > | GetAppliedControl () const final |
| Get the latest applied control. | |
| std::shared_ptr< controls::ControlRequest > | GetAppliedControl () final |
| Get the latest applied control. | |
| bool | HasResetOccurred () final |
| std::function< bool()> | GetResetOccurredChecker () const final |
| bool | IsConnected (units::second_t maxLatencySeconds=500_ms) final |
| Returns whether the device is still connected to the robot. | |
| StatusSignal< double > & | GetGenericSignal (uint32_t signal, bool refresh=true) |
| This is a reserved routine for internal testing. | |
| ctre::phoenix::StatusCode | OptimizeBusUtilization (units::frequency::hertz_t optimizedFreqHz=4_Hz, units::time::second_t timeoutSeconds=100_ms) final |
| Optimizes the device's bus utilization by reducing the update frequencies of its status signals. | |
| ctre::phoenix::StatusCode | ResetSignalFrequencies (units::time::second_t timeoutSeconds=100_ms) final |
| Resets the update frequencies of all the device's status signals to the defaults. | |
| Public Member Functions inherited from ctre::phoenix6::hardware::traits::CommonDevice | |
| virtual | ~CommonDevice ()=default |
Static Public Member Functions | |
| static CoreCANdi | None () |
| Constructs a stubbed-out CoreCANdi, where all status signals, controls, configs, etc. | |
| Static Public Member Functions inherited from ctre::phoenix6::hardware::ParentDevice | |
| template<std::derived_from< traits::CommonDevice >... Devices> | |
| static ctre::phoenix::StatusCode | OptimizeBusUtilizationForAll (Devices &... devices) |
| Optimizes the bus utilization of the provided devices by reducing the update frequencies of their status signals. | |
| static ctre::phoenix::StatusCode | OptimizeBusUtilizationForAll (std::span< traits::CommonDevice *const > devices) |
| Optimizes the bus utilization of the provided devices by reducing the update frequencies of their status signals. | |
| template<std::derived_from< traits::CommonDevice >... Devices> | |
| static ctre::phoenix::StatusCode | OptimizeBusUtilizationForAll (units::frequency::hertz_t optimizedFreqHz, Devices &... devices) |
| Optimizes the bus utilization of the provided devices by reducing the update frequencies of their status signals. | |
| static ctre::phoenix::StatusCode | OptimizeBusUtilizationForAll (units::frequency::hertz_t optimizedFreqHz, std::span< traits::CommonDevice *const > devices) |
| Optimizes the bus utilization of the provided devices by reducing the update frequencies of their status signals. | |
| template<std::derived_from< traits::CommonDevice >... Devices> | |
| static ctre::phoenix::StatusCode | ResetSignalFrequenciesForAll (Devices &... devices) |
| Resets the update frequencies of all the devices' status signals to the defaults. | |
| static ctre::phoenix::StatusCode | ResetSignalFrequenciesForAll (std::span< traits::CommonDevice *const > devices) |
| Resets the update frequencies of all the devices' status signals to the defaults. | |
Additional Inherited Members | |
| Protected Member Functions inherited from ctre::phoenix6::hardware::ParentDevice | |
| virtual ctre::phoenix::StatusCode | SetControlPrivate (controls::ControlRequest const &request) |
| template<typename T > | |
| StatusSignal< T > & | LookupStatusSignal (uint16_t spn, std::string signalName, bool reportOnConstruction, bool refresh) |
| template<typename T > | |
| StatusSignal< T > & | LookupStatusSignal (uint16_t spn, std::string signalName, std::function< std::map< uint16_t, std::string >()> mapFiller, bool reportOnConstruction, bool refresh) |
| Protected Attributes inherited from ctre::phoenix6::hardware::ParentDevice | |
| DeviceIdentifier | deviceIdentifier |
| Static Protected Attributes inherited from ctre::phoenix6::hardware::ParentDevice | |
| static constexpr controls::EmptyControl | _emptyControl {} |
Detailed Description
Class for CTR Electronics' CANdi™ branded device, a device that integrates digital signals into the existing CAN bus network.
Member Typedef Documentation
◆ Configuration
The configuration class for this device.
Constructor & Destructor Documentation
◆ CoreCANdi() [1/2]
| ctre::phoenix6::hardware::core::CoreCANdi::CoreCANdi | ( | int | deviceId, |
| CANBus | canbus = {} ) |
Constructs a new CANdi object.
- Parameters
-
deviceId ID of the device, as configured in Phoenix Tuner canbus The CAN bus this device is on
◆ CoreCANdi() [2/2]
| ctre::phoenix6::hardware::core::CoreCANdi::CoreCANdi | ( | int | deviceId, |
| std::string | canbus ) |
Constructs a new CANdi object.
- Parameters
-
deviceId ID of the device, as configured in Phoenix Tuner canbus Name of the CAN bus this device is on. Possible CAN bus strings are: - "rio" for the native roboRIO CAN bus
- CANivore name or serial number
- SocketCAN interface (non-FRC Linux only)
- "*" for any CANivore seen by the program
- empty string (default) to select the default for the system:
- "rio" on roboRIO
- "can0" on Linux
- "*" on Windows
- Deprecated
- Constructing devices with a CAN bus string is deprecated for removal in the 2027 season. Construct devices using a CANBus instance instead.
Member Function Documentation
◆ ClearStickyFault_5V() [1/2]
|
inline |
Clear sticky fault: The CTR Electronics' CANdi™ branded device has detected a 5V fault.
This may be due to overcurrent or a short-circuit.
This will wait up to 0.100 seconds (100ms) by default.
- Returns
- StatusCode of the set command
◆ ClearStickyFault_5V() [2/2]
|
inline |
Clear sticky fault: The CTR Electronics' CANdi™ branded device has detected a 5V fault.
This may be due to overcurrent or a short-circuit.
- Parameters
-
timeoutSeconds Maximum time to wait up to in seconds.
- Returns
- StatusCode of the set command
◆ ClearStickyFault_BootDuringEnable() [1/2]
|
inline |
Clear sticky fault: Device boot while detecting the enable signal.
This will wait up to 0.100 seconds (100ms) by default.
- Returns
- StatusCode of the set command
◆ ClearStickyFault_BootDuringEnable() [2/2]
|
inline |
Clear sticky fault: Device boot while detecting the enable signal.
- Parameters
-
timeoutSeconds Maximum time to wait up to in seconds.
- Returns
- StatusCode of the set command
◆ ClearStickyFault_Hardware() [1/2]
|
inline |
Clear sticky fault: Hardware fault occurred.
This will wait up to 0.100 seconds (100ms) by default.
- Returns
- StatusCode of the set command
◆ ClearStickyFault_Hardware() [2/2]
|
inline |
Clear sticky fault: Hardware fault occurred.
- Parameters
-
timeoutSeconds Maximum time to wait up to in seconds.
- Returns
- StatusCode of the set command
◆ ClearStickyFault_Undervoltage() [1/2]
|
inline |
Clear sticky fault: Device supply voltage dropped to near brownout levels.
This will wait up to 0.100 seconds (100ms) by default.
- Returns
- StatusCode of the set command
◆ ClearStickyFault_Undervoltage() [2/2]
|
inline |
Clear sticky fault: Device supply voltage dropped to near brownout levels.
- Parameters
-
timeoutSeconds Maximum time to wait up to in seconds.
- Returns
- StatusCode of the set command
◆ ClearStickyFault_UnlicensedFeatureInUse() [1/2]
|
inline |
Clear sticky fault: An unlicensed feature is in use, device may not behave as expected.
This will wait up to 0.100 seconds (100ms) by default.
- Returns
- StatusCode of the set command
◆ ClearStickyFault_UnlicensedFeatureInUse() [2/2]
|
inline |
Clear sticky fault: An unlicensed feature is in use, device may not behave as expected.
- Parameters
-
timeoutSeconds Maximum time to wait up to in seconds.
- Returns
- StatusCode of the set command
◆ ClearStickyFaults() [1/2]
|
inline |
Clear the sticky faults in the device.
This typically has no impact on the device functionality. Instead, it just clears telemetry faults that are accessible via API and Tuner Self-Test.
This will wait up to 0.100 seconds (100ms) by default.
- Returns
- StatusCode of the set command
◆ ClearStickyFaults() [2/2]
|
inline |
Clear the sticky faults in the device.
This typically has no impact on the device functionality. Instead, it just clears telemetry faults that are accessible via API and Tuner Self-Test.
- Parameters
-
timeoutSeconds Maximum time to wait up to in seconds.
- Returns
- StatusCode of the set command
◆ GetConfigurator() [1/2]
|
inline |
◆ GetConfigurator() [2/2]
|
inline |
◆ GetFault_5V()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetFault_5V | ( | bool | refresh = true | ) |
The CTR Electronics' CANdi™ branded device has detected a 5V fault.
This may be due to overcurrent or a short-circuit.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- Fault_5V Status Signal Object
◆ GetFault_BootDuringEnable()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetFault_BootDuringEnable | ( | bool | refresh = true | ) |
Device boot while detecting the enable signal.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- Fault_BootDuringEnable Status Signal Object
◆ GetFault_Hardware()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetFault_Hardware | ( | bool | refresh = true | ) |
Hardware fault occurred.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- Fault_Hardware Status Signal Object
◆ GetFault_Undervoltage()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetFault_Undervoltage | ( | bool | refresh = true | ) |
Device supply voltage dropped to near brownout levels.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- Fault_Undervoltage Status Signal Object
◆ GetFault_UnlicensedFeatureInUse()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetFault_UnlicensedFeatureInUse | ( | bool | refresh = true | ) |
An unlicensed feature is in use, device may not behave as expected.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- Fault_UnlicensedFeatureInUse Status Signal Object
◆ GetFaultField()
| StatusSignal< int > & ctre::phoenix6::hardware::core::CoreCANdi::GetFaultField | ( | bool | refresh = true | ) |
Integer representing all fault flags reported by the device.
These are device specific and are not used directly in typical applications. Use the signal specific GetFault_*() methods instead.
- Minimum Value: 0
- Maximum Value: 4294967295
- Default Value: 0
- Units:
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- FaultField Status Signal Object
◆ GetIsProLicensed()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetIsProLicensed | ( | bool | refresh = true | ) |
Whether the device is Phoenix Pro licensed.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- IsProLicensed Status Signal Object
◆ GetOutputCurrent()
| StatusSignal< units::current::ampere_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetOutputCurrent | ( | bool | refresh = true | ) |
Measured output current.
This includes both Vbat and 5V output current.
- Minimum Value: 0.0
- Maximum Value: 0.51
- Default Value: 0
- Units: A
Default Rates:
- CAN 2.0: 100.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- OutputCurrent Status Signal Object
◆ GetOvercurrent()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetOvercurrent | ( | bool | refresh = true | ) |
True when the CANdi™ is in overcurrent protection mode.
This may be due to either overcurrent or a short-circuit.
- Default Value: 0
Default Rates:
- CAN 2.0: 100.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- Overcurrent Status Signal Object
◆ GetPWM1Position()
| StatusSignal< units::angle::turn_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetPWM1Position | ( | bool | refresh = true | ) |
Measured position of the PWM sensor at the S1 input of the CTR Electronics' CANdi™.
- Minimum Value: -16384.0
- Maximum Value: 16383.999755859375
- Default Value: 0
- Units: rotations
Default Rates:
- CAN 2.0: 20.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- PWM1Position Status Signal Object
◆ GetPWM1RiseToRise()
| StatusSignal< units::time::microsecond_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetPWM1RiseToRise | ( | bool | refresh = true | ) |
Measured rise to rise time of the PWM signal at the S1 input of the CTR Electronics' CANdi™.
- Minimum Value: 0
- Maximum Value: 131070
- Default Value: 0
- Units: us
Default Rates:
- CAN 2.0: 20.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- PWM1RiseToRise Status Signal Object
◆ GetPWM1Velocity()
| StatusSignal< units::angular_velocity::turns_per_second_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetPWM1Velocity | ( | bool | refresh = true | ) |
Measured velocity of the PWM sensor at the S1 input of the CTR Electronics' CANdi™.
- Minimum Value: -512.0
- Maximum Value: 511.998046875
- Default Value: 0
- Units: rotations per second
Default Rates:
- CAN 2.0: 20.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- PWM1Velocity Status Signal Object
◆ GetPWM2Position()
| StatusSignal< units::angle::turn_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetPWM2Position | ( | bool | refresh = true | ) |
Measured position of the PWM sensor at the S2 input of the CTR Electronics' CANdi™.
- Minimum Value: -16384.0
- Maximum Value: 16383.999755859375
- Default Value: 0
- Units: rotations
Default Rates:
- CAN 2.0: 20.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- PWM2Position Status Signal Object
◆ GetPWM2RiseToRise()
| StatusSignal< units::time::microsecond_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetPWM2RiseToRise | ( | bool | refresh = true | ) |
Measured rise to rise time of the PWM signal at the S2 input of the CTR Electronics' CANdi™.
- Minimum Value: 0
- Maximum Value: 131070
- Default Value: 0
- Units: us
Default Rates:
- CAN 2.0: 20.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- PWM2RiseToRise Status Signal Object
◆ GetPWM2Velocity()
| StatusSignal< units::angular_velocity::turns_per_second_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetPWM2Velocity | ( | bool | refresh = true | ) |
Measured velocity of the PWM sensor at the S2 input of the CTR Electronics' CANdi™.
- Minimum Value: -512.0
- Maximum Value: 511.998046875
- Default Value: 0
- Units: rotations per second
Default Rates:
- CAN 2.0: 20.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- PWM2Velocity Status Signal Object
◆ GetQuadraturePosition()
| StatusSignal< units::angle::turn_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetQuadraturePosition | ( | bool | refresh = true | ) |
Position from a quadrature encoder sensor connected to both the S1IN and S2IN inputs.
- Minimum Value: -16384.0
- Maximum Value: 16383.999755859375
- Default Value: 0
- Units: rotations
Default Rates:
- CAN 2.0: 20.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- QuadraturePosition Status Signal Object
◆ GetQuadratureVelocity()
| StatusSignal< units::angular_velocity::turns_per_second_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetQuadratureVelocity | ( | bool | refresh = true | ) |
Velocity from a quadrature encoder sensor connected to both the S1IN and S2IN inputs.
- Minimum Value: -512.0
- Maximum Value: 511.998046875
- Default Value: 0
- Units: rotations per second
Default Rates:
- CAN 2.0: 20.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- QuadratureVelocity Status Signal Object
◆ GetS1Closed()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetS1Closed | ( | bool | refresh = true | ) |
True if the Signal 1 input (S1IN) matches the configured S1 Closed State.
Configure the S1 closed state in the Digitals configuration object to change when this is asserted.
- Default Value: False
Default Rates:
- CAN 2.0: 100.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- S1Closed Status Signal Object
◆ GetS1State()
| StatusSignal< signals::S1StateValue > & ctre::phoenix6::hardware::core::CoreCANdi::GetS1State | ( | bool | refresh = true | ) |
State of the Signal 1 input (S1IN).
Default Rates:
- CAN 2.0: 100.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- S1State Status Signal Object
◆ GetS2Closed()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetS2Closed | ( | bool | refresh = true | ) |
True if the Signal 2 input (S2IN) matches the configured S2 Closed State.
Configure the S2 closed state in the Digitals configuration object to change when this is asserted.
- Default Value: False
Default Rates:
- CAN 2.0: 100.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- S2Closed Status Signal Object
◆ GetS2State()
| StatusSignal< signals::S2StateValue > & ctre::phoenix6::hardware::core::CoreCANdi::GetS2State | ( | bool | refresh = true | ) |
State of the Signal 2 input (S2IN).
Default Rates:
- CAN 2.0: 100.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- S2State Status Signal Object
◆ GetSimState()
|
inline |
Get the simulation state for this device.
This function reuses an allocated simulation state object, so it is safe to call this function multiple times in a robot loop.
- Returns
- Simulation state
◆ GetStickyFault_5V()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetStickyFault_5V | ( | bool | refresh = true | ) |
The CTR Electronics' CANdi™ branded device has detected a 5V fault.
This may be due to overcurrent or a short-circuit.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- StickyFault_5V Status Signal Object
◆ GetStickyFault_BootDuringEnable()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetStickyFault_BootDuringEnable | ( | bool | refresh = true | ) |
Device boot while detecting the enable signal.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- StickyFault_BootDuringEnable Status Signal Object
◆ GetStickyFault_Hardware()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetStickyFault_Hardware | ( | bool | refresh = true | ) |
Hardware fault occurred.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- StickyFault_Hardware Status Signal Object
◆ GetStickyFault_Undervoltage()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetStickyFault_Undervoltage | ( | bool | refresh = true | ) |
Device supply voltage dropped to near brownout levels.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- StickyFault_Undervoltage Status Signal Object
◆ GetStickyFault_UnlicensedFeatureInUse()
| StatusSignal< bool > & ctre::phoenix6::hardware::core::CoreCANdi::GetStickyFault_UnlicensedFeatureInUse | ( | bool | refresh = true | ) |
An unlicensed feature is in use, device may not behave as expected.
- Default Value: False
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- StickyFault_UnlicensedFeatureInUse Status Signal Object
◆ GetStickyFaultField()
| StatusSignal< int > & ctre::phoenix6::hardware::core::CoreCANdi::GetStickyFaultField | ( | bool | refresh = true | ) |
Integer representing all (persistent) sticky fault flags reported by the device.
These are device specific and are not used directly in typical applications. Use the signal specific GetStickyFault_*() methods instead.
- Minimum Value: 0
- Maximum Value: 4294967295
- Default Value: 0
- Units:
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- StickyFaultField Status Signal Object
◆ GetSupplyVoltage()
| StatusSignal< units::voltage::volt_t > & ctre::phoenix6::hardware::core::CoreCANdi::GetSupplyVoltage | ( | bool | refresh = true | ) |
Measured supply voltage to the CANdi™.
- Minimum Value: 4.0
- Maximum Value: 29.5
- Default Value: 0
- Units: V
Default Rates:
- CAN 2.0: 100.0 Hz
- CAN FD: 100.0 Hz (TimeSynced with Pro)
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- SupplyVoltage Status Signal Object
◆ GetVersion()
| StatusSignal< int > & ctre::phoenix6::hardware::core::CoreCANdi::GetVersion | ( | bool | refresh = true | ) |
Full Version of firmware in device.
The format is a four byte value.
- Minimum Value: 0
- Maximum Value: 4294967295
- Default Value: 0
- Units:
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- Version Status Signal Object
◆ GetVersionBugfix()
| StatusSignal< int > & ctre::phoenix6::hardware::core::CoreCANdi::GetVersionBugfix | ( | bool | refresh = true | ) |
App Bugfix Version number.
- Minimum Value: 0
- Maximum Value: 255
- Default Value: 0
- Units:
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- VersionBugfix Status Signal Object
◆ GetVersionBuild()
| StatusSignal< int > & ctre::phoenix6::hardware::core::CoreCANdi::GetVersionBuild | ( | bool | refresh = true | ) |
App Build Version number.
- Minimum Value: 0
- Maximum Value: 255
- Default Value: 0
- Units:
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- VersionBuild Status Signal Object
◆ GetVersionMajor()
| StatusSignal< int > & ctre::phoenix6::hardware::core::CoreCANdi::GetVersionMajor | ( | bool | refresh = true | ) |
App Major Version number.
- Minimum Value: 0
- Maximum Value: 255
- Default Value: 0
- Units:
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- VersionMajor Status Signal Object
◆ GetVersionMinor()
| StatusSignal< int > & ctre::phoenix6::hardware::core::CoreCANdi::GetVersionMinor | ( | bool | refresh = true | ) |
App Minor Version number.
- Minimum Value: 0
- Maximum Value: 255
- Default Value: 0
- Units:
Default Rates:
- CAN: 4.0 Hz
This refreshes and returns a cached StatusSignal object.
- Parameters
-
refresh Whether to refresh the StatusSignal before returning it; defaults to true
- Returns
- VersionMinor Status Signal Object
◆ None()
|
inlinestatic |
◆ SetQuadraturePosition() [1/2]
|
inline |
Sets the position of the quadrature input.
This will wait up to 0.100 seconds (100ms) by default.
- Parameters
-
newValue Value to set to. Units are in rotations.
- Returns
- StatusCode of the set command
◆ SetQuadraturePosition() [2/2]
|
inline |
Sets the position of the quadrature input.
- Parameters
-
newValue Value to set to. Units are in rotations. timeoutSeconds Maximum time to wait up to in seconds.
- Returns
- StatusCode of the set command
The documentation for this class was generated from the following file:
- ctre/phoenix6/core/CoreCANdi.hpp