Contains everything common between Talon motor controllers that support FOC (requires Phoenix Pro). More...
#include <ctre/phoenix6/hardware/traits/CommonTalonWithFOC.hpp>
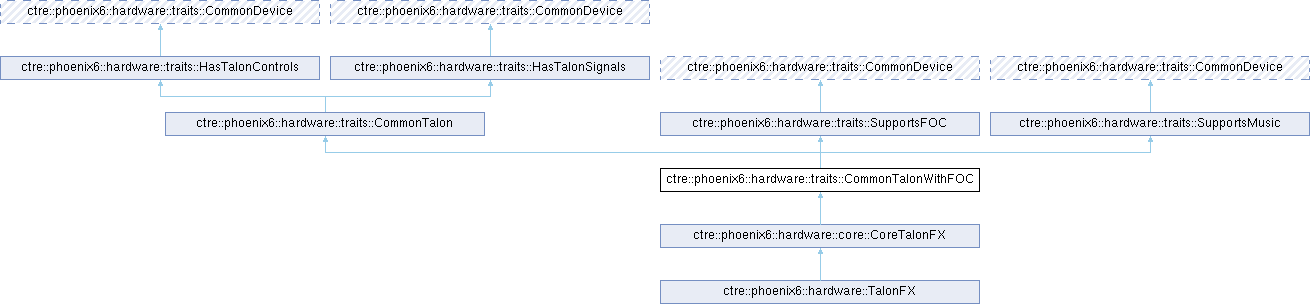
Public Member Functions | |
| virtual | ~CommonTalonWithFOC ()=default |
| virtual ctre::phoenix::StatusCode | SetControl (controls::TorqueCurrentFOC const &request)=0 |
| Request a specified motor current (field oriented control). | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::PositionTorqueCurrentFOC const &request)=0 |
| Request PID to target position with torque current feedforward. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::VelocityTorqueCurrentFOC const &request)=0 |
| Request PID to target velocity with torque current feedforward. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MotionMagicTorqueCurrentFOC const &request)=0 |
| Requests Motion Magic® to target a final position using a motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MotionMagicVelocityTorqueCurrentFOC const &request)=0 |
| Requests Motion Magic® to target a final velocity using a motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MotionMagicExpoTorqueCurrentFOC const &request)=0 |
| Requests Motion Magic® to target a final position using an exponential motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DynamicMotionMagicTorqueCurrentFOC const &request)=0 |
| Requests Motion Magic® to target a final position using a motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DynamicMotionMagicExpoTorqueCurrentFOC const &request)=0 |
| Requests Motion Magic® Expo to target a final position using an exponential motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_TorqueCurrentFOC_Position const &request)=0 |
| Differential control with torque current average target and position difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_PositionTorqueCurrentFOC_Position const &request)=0 |
| Differential control with position average target and position difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VelocityTorqueCurrentFOC_Position const &request)=0 |
| Differential control with velocity average target and position difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicTorqueCurrentFOC_Position const &request)=0 |
| Differential control with Motion Magic® average target and position difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicExpoTorqueCurrentFOC_Position const &request)=0 |
| Differential control with Motion Magic® Expo average target and position difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVelocityTorqueCurrentFOC_Position const &request)=0 |
| Differential control with Motion Magic® Velocity average target and position difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_TorqueCurrentFOC_Velocity const &request)=0 |
| Differential control with torque current average target and velocity difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_PositionTorqueCurrentFOC_Velocity const &request)=0 |
| Differential control with position average target and velocity difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VelocityTorqueCurrentFOC_Velocity const &request)=0 |
| Differential control with velocity average target and velocity difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicTorqueCurrentFOC_Velocity const &request)=0 |
| Differential control with Motion Magic® average target and velocity difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicExpoTorqueCurrentFOC_Velocity const &request)=0 |
| Differential control with Motion Magic® Expo average target and velocity difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVelocityTorqueCurrentFOC_Velocity const &request)=0 |
| Differential control with Motion Magic® Velocity average target and velocity difference target using torque current control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_TorqueCurrentFOC_Open const &request)=0 |
| Differential control with torque current average target and torque current difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_PositionTorqueCurrentFOC_Open const &request)=0 |
| Differential control with position average target and torque current difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VelocityTorqueCurrentFOC_Open const &request)=0 |
| Differential control with velocity average target and torque current difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicTorqueCurrentFOC_Open const &request)=0 |
| Differential control with Motion Magic® average target and torque current difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicExpoTorqueCurrentFOC_Open const &request)=0 |
| Differential control with Motion Magic® Expo average target and torque current difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVelocityTorqueCurrentFOC_Open const &request)=0 |
| Differential control with Motion Magic® Velocity average target and torque current difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::EmptyControl const &request)=0 |
| Apply a generic empty control used to do nothing. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::ControlRequest const &request)=0 |
| Control device with generic control request object. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MusicTone const &request)=0 |
| Plays a single tone at the user specified frequency. | |
 Public Member Functions inherited from ctre::phoenix6::hardware::traits::CommonTalon | |
| virtual | ~CommonTalon ()=default |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DutyCycleOut const &request)=0 |
| Request a specified motor duty cycle. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::VoltageOut const &request)=0 |
| Request a specified voltage. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::PositionDutyCycle const &request)=0 |
| Request PID to target position with duty cycle feedforward. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::PositionVoltage const &request)=0 |
| Request PID to target position with voltage feedforward. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::VelocityDutyCycle const &request)=0 |
| Request PID to target velocity with duty cycle feedforward. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::VelocityVoltage const &request)=0 |
| Request PID to target velocity with voltage feedforward. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MotionMagicDutyCycle const &request)=0 |
| Requests Motion Magic® to target a final position using a motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MotionMagicVoltage const &request)=0 |
| Requests Motion Magic® to target a final position using a motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MotionMagicVelocityDutyCycle const &request)=0 |
| Requests Motion Magic® to target a final velocity using a motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MotionMagicVelocityVoltage const &request)=0 |
| Requests Motion Magic® to target a final velocity using a motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MotionMagicExpoDutyCycle const &request)=0 |
| Requests Motion Magic® to target a final position using an exponential motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::MotionMagicExpoVoltage const &request)=0 |
| Requests Motion Magic® to target a final position using an exponential motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DynamicMotionMagicDutyCycle const &request)=0 |
| Requests Motion Magic® to target a final position using a motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DynamicMotionMagicVoltage const &request)=0 |
| Requests Motion Magic® to target a final position using a motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DynamicMotionMagicExpoDutyCycle const &request)=0 |
| Requests Motion Magic® Expo to target a final position using an exponential motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DynamicMotionMagicExpoVoltage const &request)=0 |
| Requests Motion Magic® Expo to target a final position using an exponential motion profile. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialDutyCycle const &request)=0 |
| Request a specified motor duty cycle with a differential position closed-loop. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialVoltage const &request)=0 |
| Request a specified voltage with a differential position closed-loop. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialPositionDutyCycle const &request)=0 |
| Request PID to target position with a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialPositionVoltage const &request)=0 |
| Request PID to target position with a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialVelocityDutyCycle const &request)=0 |
| Request PID to target velocity with a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialVelocityVoltage const &request)=0 |
| Request PID to target velocity with a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialMotionMagicDutyCycle const &request)=0 |
| Requests Motion Magic® to target a final position using a motion profile, and PID to a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialMotionMagicVoltage const &request)=0 |
| Requests Motion Magic® to target a final position using a motion profile, and PID to a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialMotionMagicExpoDutyCycle const &request)=0 |
| Requests Motion Magic® to target a final position using an exponential motion profile, and PID to a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialMotionMagicExpoVoltage const &request)=0 |
| Requests Motion Magic® to target a final position using an exponential motion profile, and PID to a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialMotionMagicVelocityDutyCycle const &request)=0 |
| Requests Motion Magic® to target a final velocity using a motion profile, and PID to a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialMotionMagicVelocityVoltage const &request)=0 |
| Requests Motion Magic® to target a final velocity using a motion profile, and PID to a differential position setpoint. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::Follower const &request)=0 |
| Follow the motor output of another Talon. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::StrictFollower const &request)=0 |
| Follow the motor output of another Talon while ignoring the leader's invert setting. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialFollower const &request)=0 |
| Follow the differential motor output of another Talon. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::DifferentialStrictFollower const &request)=0 |
| Follow the differential motor output of another Talon while ignoring the leader's invert setting. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::StaticBrake const &request)=0 |
| Applies full neutral-brake by shorting motor leads together. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::NeutralOut const &request)=0 |
| Request neutral output of actuator. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::CoastOut const &request)=0 |
| Request coast neutral output of actuator. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_DutyCycleOut_Position const &request)=0 |
| Differential control with duty cycle average target and position difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_PositionDutyCycle_Position const &request)=0 |
| Differential control with position average target and position difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VelocityDutyCycle_Position const &request)=0 |
| Differential control with velocity average target and position difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicDutyCycle_Position const &request)=0 |
| Differential control with Motion Magic® average target and position difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicExpoDutyCycle_Position const &request)=0 |
| Differential control with Motion Magic® Expo average target and position difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVelocityDutyCycle_Position const &request)=0 |
| Differential control with Motion Magic® Velocity average target and position difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_DutyCycleOut_Velocity const &request)=0 |
| Differential control with duty cycle average target and velocity difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_PositionDutyCycle_Velocity const &request)=0 |
| Differential control with position average target and velocity difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VelocityDutyCycle_Velocity const &request)=0 |
| Differential control with velocity average target and velocity difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicDutyCycle_Velocity const &request)=0 |
| Differential control with Motion Magic® average target and velocity difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicExpoDutyCycle_Velocity const &request)=0 |
| Differential control with Motion Magic® Expo average target and velocity difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVelocityDutyCycle_Velocity const &request)=0 |
| Differential control with Motion Magic® Velocity average target and velocity difference target using duty cycle control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_DutyCycleOut_Open const &request)=0 |
| Differential control with duty cycle average target and duty cycle difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_PositionDutyCycle_Open const &request)=0 |
| Differential control with position average target and duty cycle difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VelocityDutyCycle_Open const &request)=0 |
| Differential control with velocity average target and duty cycle difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicDutyCycle_Open const &request)=0 |
| Differential control with Motion Magic® average target and duty cycle difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicExpoDutyCycle_Open const &request)=0 |
| Differential control with Motion Magic® Expo average target and duty cycle difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVelocityDutyCycle_Open const &request)=0 |
| Differential control with Motion Magic® Velocity average target and duty cycle difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VoltageOut_Position const &request)=0 |
| Differential control with voltage average target and position difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_PositionVoltage_Position const &request)=0 |
| Differential control with position average target and position difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VelocityVoltage_Position const &request)=0 |
| Differential control with velocity average target and position difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVoltage_Position const &request)=0 |
| Differential control with Motion Magic® average target and position difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicExpoVoltage_Position const &request)=0 |
| Differential control with Motion Magic® Expo average target and position difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVelocityVoltage_Position const &request)=0 |
| Differential control with Motion Magic® Velocity average target and position difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VoltageOut_Velocity const &request)=0 |
| Differential control with voltage average target and velocity difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_PositionVoltage_Velocity const &request)=0 |
| Differential control with position average target and velocity difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VelocityVoltage_Velocity const &request)=0 |
| Differential control with velocity average target and velocity difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVoltage_Velocity const &request)=0 |
| Differential control with Motion Magic® average target and velocity difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicExpoVoltage_Velocity const &request)=0 |
| Differential control with Motion Magic® Expo average target and velocity difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVelocityVoltage_Velocity const &request)=0 |
| Differential control with Motion Magic® Velocity average target and velocity difference target using voltage control. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VoltageOut_Open const &request)=0 |
| Differential control with voltage average target and voltage difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_PositionVoltage_Open const &request)=0 |
| Differential control with position average target and voltage difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_VelocityVoltage_Open const &request)=0 |
| Differential control with velocity average target and voltage difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVoltage_Open const &request)=0 |
| Differential control with Motion Magic® average target and voltage difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicExpoVoltage_Open const &request)=0 |
| Differential control with Motion Magic® Expo average target and voltage difference target. | |
| virtual ctre::phoenix::StatusCode | SetControl (controls::compound::Diff_MotionMagicVelocityVoltage_Open const &request)=0 |
| Differential control with Motion Magic® Velocity average target and voltage difference target. | |
| Public Member Functions inherited from ctre::phoenix6::hardware::traits::HasTalonControls | |
| virtual | ~HasTalonControls ()=default |
| Public Member Functions inherited from ctre::phoenix6::hardware::traits::CommonDevice | |
| virtual | ~CommonDevice ()=default |
| virtual int | GetDeviceID () const =0 |
| virtual CANBus | GetNetwork () const =0 |
| virtual uint64_t | GetDeviceHash () const =0 |
| Gets a number unique for this device's hardware type and ID. | |
| virtual std::shared_ptr< controls::ControlRequest const > | GetAppliedControl () const =0 |
| Get the latest applied control. | |
| virtual std::shared_ptr< controls::ControlRequest > | GetAppliedControl ()=0 |
| Get the latest applied control. | |
| virtual bool | HasResetOccurred ()=0 |
| virtual std::function< bool()> | GetResetOccurredChecker () const =0 |
| virtual bool | IsConnected (units::second_t maxLatencySeconds=500_ms)=0 |
| Returns whether the device is still connected to the robot. | |
| virtual ctre::phoenix::StatusCode | OptimizeBusUtilization (units::frequency::hertz_t optimizedFreqHz=4_Hz, units::time::second_t timeoutSeconds=100_ms)=0 |
| Optimizes the device's bus utilization by reducing the update frequencies of its status signals. | |
| virtual ctre::phoenix::StatusCode | ResetSignalFrequencies (units::time::second_t timeoutSeconds=100_ms)=0 |
| Resets the update frequencies of all the device's status signals to the defaults. | |
| Public Member Functions inherited from ctre::phoenix6::hardware::traits::HasTalonSignals | |
| virtual | ~HasTalonSignals ()=default |
| virtual StatusSignal< int > & | GetVersionMajor (bool refresh=true)=0 |
| App Major Version number. | |
| virtual StatusSignal< int > & | GetVersionMinor (bool refresh=true)=0 |
| App Minor Version number. | |
| virtual StatusSignal< int > & | GetVersionBugfix (bool refresh=true)=0 |
| App Bugfix Version number. | |
| virtual StatusSignal< int > & | GetVersionBuild (bool refresh=true)=0 |
| App Build Version number. | |
| virtual StatusSignal< int > & | GetVersion (bool refresh=true)=0 |
| Full Version of firmware in device. | |
| virtual StatusSignal< int > & | GetFaultField (bool refresh=true)=0 |
| Integer representing all fault flags reported by the device. | |
| virtual StatusSignal< int > & | GetStickyFaultField (bool refresh=true)=0 |
| Integer representing all (persistent) sticky fault flags reported by the device. | |
| virtual StatusSignal< units::voltage::volt_t > & | GetMotorVoltage (bool refresh=true)=0 |
| The applied (output) motor voltage. | |
| virtual StatusSignal< signals::ForwardLimitValue > & | GetForwardLimit (bool refresh=true)=0 |
| Forward Limit Pin. | |
| virtual StatusSignal< signals::ReverseLimitValue > & | GetReverseLimit (bool refresh=true)=0 |
| Reverse Limit Pin. | |
| virtual StatusSignal< signals::AppliedRotorPolarityValue > & | GetAppliedRotorPolarity (bool refresh=true)=0 |
| The applied rotor polarity as seen from the front of the motor. | |
| virtual StatusSignal< units::dimensionless::scalar_t > & | GetDutyCycle (bool refresh=true)=0 |
| The applied motor duty cycle. | |
| virtual StatusSignal< units::current::ampere_t > & | GetTorqueCurrent (bool refresh=true)=0 |
| Current corresponding to the torque output by the motor. | |
| virtual StatusSignal< units::current::ampere_t > & | GetStatorCurrent (bool refresh=true)=0 |
| Current corresponding to the stator windings. | |
| virtual StatusSignal< units::current::ampere_t > & | GetSupplyCurrent (bool refresh=true)=0 |
| Measured supply side current. | |
| virtual StatusSignal< units::voltage::volt_t > & | GetSupplyVoltage (bool refresh=true)=0 |
| Measured supply voltage to the device. | |
| virtual StatusSignal< units::temperature::celsius_t > & | GetDeviceTemp (bool refresh=true)=0 |
| Temperature of device. | |
| virtual StatusSignal< units::temperature::celsius_t > & | GetProcessorTemp (bool refresh=true)=0 |
| Temperature of the processor. | |
| virtual StatusSignal< units::angular_velocity::turns_per_second_t > & | GetRotorVelocity (bool refresh=true)=0 |
| Velocity of the motor rotor. | |
| virtual StatusSignal< units::angle::turn_t > & | GetRotorPosition (bool refresh=true)=0 |
| Position of the motor rotor. | |
| virtual StatusSignal< units::angular_velocity::turns_per_second_t > & | GetVelocity (bool refresh=true)=0 |
| Velocity of the device in mechanism rotations per second. | |
| virtual StatusSignal< units::angle::turn_t > & | GetPosition (bool refresh=true)=0 |
| Position of the device in mechanism rotations. | |
| virtual StatusSignal< units::angular_acceleration::turns_per_second_squared_t > & | GetAcceleration (bool refresh=true)=0 |
| Acceleration of the device in mechanism rotations per second². | |
| virtual StatusSignal< signals::ControlModeValue > & | GetControlMode (bool refresh=true)=0 |
| The active control mode of the motor controller. | |
| virtual StatusSignal< bool > & | GetMotionMagicAtTarget (bool refresh=true)=0 |
| Check if the Motion Magic® profile has reached the target. | |
| virtual StatusSignal< bool > & | GetMotionMagicIsRunning (bool refresh=true)=0 |
| Check if Motion Magic® is running. | |
| virtual StatusSignal< signals::RobotEnableValue > & | GetRobotEnable (bool refresh=true)=0 |
| Indicates if the robot is enabled. | |
| virtual StatusSignal< signals::DeviceEnableValue > & | GetDeviceEnable (bool refresh=true)=0 |
| Indicates if device is actuator enabled. | |
| virtual StatusSignal< int > & | GetClosedLoopSlot (bool refresh=true)=0 |
| The slot that the closed-loop PID is using. | |
| virtual StatusSignal< signals::MotorOutputStatusValue > & | GetMotorOutputStatus (bool refresh=true)=0 |
| Assess the status of the motor output with respect to load and supply. | |
| virtual StatusSignal< signals::DifferentialControlModeValue > & | GetDifferentialControlMode (bool refresh=true)=0 |
| The active control mode of the differential controller. | |
| virtual StatusSignal< units::angular_velocity::turns_per_second_t > & | GetDifferentialAverageVelocity (bool refresh=true)=0 |
| Average component of the differential velocity of device. | |
| virtual StatusSignal< units::angle::turn_t > & | GetDifferentialAveragePosition (bool refresh=true)=0 |
| Average component of the differential position of device. | |
| virtual StatusSignal< units::angular_velocity::turns_per_second_t > & | GetDifferentialDifferenceVelocity (bool refresh=true)=0 |
| Difference component of the differential velocity of device. | |
| virtual StatusSignal< units::angle::turn_t > & | GetDifferentialDifferencePosition (bool refresh=true)=0 |
| Difference component of the differential position of device. | |
| virtual StatusSignal< int > & | GetDifferentialClosedLoopSlot (bool refresh=true)=0 |
| The slot that the closed-loop differential PID is using. | |
| virtual StatusSignal< ctre::unit::newton_meters_per_ampere_t > & | GetMotorKT (bool refresh=true)=0 |
| The torque constant (K_T) of the motor. | |
| virtual StatusSignal< ctre::unit::rpm_per_volt_t > & | GetMotorKV (bool refresh=true)=0 |
| The velocity constant (K_V) of the motor. | |
| virtual StatusSignal< units::current::ampere_t > & | GetMotorStallCurrent (bool refresh=true)=0 |
| The stall current of the motor at 12 V output. | |
| virtual StatusSignal< signals::BridgeOutputValue > & | GetBridgeOutput (bool refresh=true)=0 |
| The applied output of the bridge. | |
| virtual StatusSignal< bool > & | GetIsProLicensed (bool refresh=true)=0 |
| Whether the device is Phoenix Pro licensed. | |
| virtual StatusSignal< units::temperature::celsius_t > & | GetAncillaryDeviceTemp (bool refresh=true)=0 |
| Temperature of device from second sensor. | |
| virtual StatusSignal< signals::ConnectedMotorValue > & | GetConnectedMotor (bool refresh=true)=0 |
| The type of motor attached to the Talon. | |
| virtual StatusSignal< bool > & | GetFault_Hardware (bool refresh=true)=0 |
| Hardware fault occurred. | |
| virtual StatusSignal< bool > & | GetStickyFault_Hardware (bool refresh=true)=0 |
| Hardware fault occurred. | |
| virtual StatusSignal< bool > & | GetFault_ProcTemp (bool refresh=true)=0 |
| Processor temperature exceeded limit. | |
| virtual StatusSignal< bool > & | GetStickyFault_ProcTemp (bool refresh=true)=0 |
| Processor temperature exceeded limit. | |
| virtual StatusSignal< bool > & | GetFault_DeviceTemp (bool refresh=true)=0 |
| Device temperature exceeded limit. | |
| virtual StatusSignal< bool > & | GetStickyFault_DeviceTemp (bool refresh=true)=0 |
| Device temperature exceeded limit. | |
| virtual StatusSignal< bool > & | GetFault_Undervoltage (bool refresh=true)=0 |
| Device supply voltage dropped to near brownout levels. | |
| virtual StatusSignal< bool > & | GetStickyFault_Undervoltage (bool refresh=true)=0 |
| Device supply voltage dropped to near brownout levels. | |
| virtual StatusSignal< bool > & | GetFault_BootDuringEnable (bool refresh=true)=0 |
| Device boot while detecting the enable signal. | |
| virtual StatusSignal< bool > & | GetStickyFault_BootDuringEnable (bool refresh=true)=0 |
| Device boot while detecting the enable signal. | |
| virtual StatusSignal< bool > & | GetFault_UnlicensedFeatureInUse (bool refresh=true)=0 |
| An unlicensed feature is in use, device may not behave as expected. | |
| virtual StatusSignal< bool > & | GetStickyFault_UnlicensedFeatureInUse (bool refresh=true)=0 |
| An unlicensed feature is in use, device may not behave as expected. | |
| virtual StatusSignal< bool > & | GetFault_BridgeBrownout (bool refresh=true)=0 |
| Bridge was disabled most likely due to supply voltage dropping too low. | |
| virtual StatusSignal< bool > & | GetStickyFault_BridgeBrownout (bool refresh=true)=0 |
| Bridge was disabled most likely due to supply voltage dropping too low. | |
| virtual StatusSignal< bool > & | GetFault_RemoteSensorReset (bool refresh=true)=0 |
| The remote sensor has reset. | |
| virtual StatusSignal< bool > & | GetStickyFault_RemoteSensorReset (bool refresh=true)=0 |
| The remote sensor has reset. | |
| virtual StatusSignal< bool > & | GetFault_MissingDifferentialFX (bool refresh=true)=0 |
| The remote Talon used for differential control is not present on CAN Bus. | |
| virtual StatusSignal< bool > & | GetStickyFault_MissingDifferentialFX (bool refresh=true)=0 |
| The remote Talon used for differential control is not present on CAN Bus. | |
| virtual StatusSignal< bool > & | GetFault_RemoteSensorPosOverflow (bool refresh=true)=0 |
| The remote sensor position has overflowed. | |
| virtual StatusSignal< bool > & | GetStickyFault_RemoteSensorPosOverflow (bool refresh=true)=0 |
| The remote sensor position has overflowed. | |
| virtual StatusSignal< bool > & | GetFault_OverSupplyV (bool refresh=true)=0 |
| Supply Voltage has exceeded the maximum voltage rating of device. | |
| virtual StatusSignal< bool > & | GetStickyFault_OverSupplyV (bool refresh=true)=0 |
| Supply Voltage has exceeded the maximum voltage rating of device. | |
| virtual StatusSignal< bool > & | GetFault_UnstableSupplyV (bool refresh=true)=0 |
| Supply Voltage is unstable. | |
| virtual StatusSignal< bool > & | GetStickyFault_UnstableSupplyV (bool refresh=true)=0 |
| Supply Voltage is unstable. | |
| virtual StatusSignal< bool > & | GetFault_ReverseHardLimit (bool refresh=true)=0 |
| Reverse limit switch has been asserted. | |
| virtual StatusSignal< bool > & | GetStickyFault_ReverseHardLimit (bool refresh=true)=0 |
| Reverse limit switch has been asserted. | |
| virtual StatusSignal< bool > & | GetFault_ForwardHardLimit (bool refresh=true)=0 |
| Forward limit switch has been asserted. | |
| virtual StatusSignal< bool > & | GetStickyFault_ForwardHardLimit (bool refresh=true)=0 |
| Forward limit switch has been asserted. | |
| virtual StatusSignal< bool > & | GetFault_ReverseSoftLimit (bool refresh=true)=0 |
| Reverse soft limit has been asserted. | |
| virtual StatusSignal< bool > & | GetStickyFault_ReverseSoftLimit (bool refresh=true)=0 |
| Reverse soft limit has been asserted. | |
| virtual StatusSignal< bool > & | GetFault_ForwardSoftLimit (bool refresh=true)=0 |
| Forward soft limit has been asserted. | |
| virtual StatusSignal< bool > & | GetStickyFault_ForwardSoftLimit (bool refresh=true)=0 |
| Forward soft limit has been asserted. | |
| virtual StatusSignal< bool > & | GetFault_MissingSoftLimitRemote (bool refresh=true)=0 |
| The remote soft limit device is not present on CAN Bus. | |
| virtual StatusSignal< bool > & | GetStickyFault_MissingSoftLimitRemote (bool refresh=true)=0 |
| The remote soft limit device is not present on CAN Bus. | |
| virtual StatusSignal< bool > & | GetFault_MissingHardLimitRemote (bool refresh=true)=0 |
| The remote limit switch device is not present on CAN Bus. | |
| virtual StatusSignal< bool > & | GetStickyFault_MissingHardLimitRemote (bool refresh=true)=0 |
| The remote limit switch device is not present on CAN Bus. | |
| virtual StatusSignal< bool > & | GetFault_RemoteSensorDataInvalid (bool refresh=true)=0 |
| The remote sensor's data is no longer trusted. | |
| virtual StatusSignal< bool > & | GetStickyFault_RemoteSensorDataInvalid (bool refresh=true)=0 |
| The remote sensor's data is no longer trusted. | |
| virtual StatusSignal< bool > & | GetFault_FusedSensorOutOfSync (bool refresh=true)=0 |
| The remote sensor used for fusion has fallen out of sync to the local sensor. | |
| virtual StatusSignal< bool > & | GetStickyFault_FusedSensorOutOfSync (bool refresh=true)=0 |
| The remote sensor used for fusion has fallen out of sync to the local sensor. | |
| virtual StatusSignal< bool > & | GetFault_StatorCurrLimit (bool refresh=true)=0 |
| Stator current limit occured. | |
| virtual StatusSignal< bool > & | GetStickyFault_StatorCurrLimit (bool refresh=true)=0 |
| Stator current limit occured. | |
| virtual StatusSignal< bool > & | GetFault_SupplyCurrLimit (bool refresh=true)=0 |
| Supply current limit occured. | |
| virtual StatusSignal< bool > & | GetStickyFault_SupplyCurrLimit (bool refresh=true)=0 |
| Supply current limit occured. | |
| virtual StatusSignal< bool > & | GetFault_UsingFusedCANcoderWhileUnlicensed (bool refresh=true)=0 |
| Using Fused CANcoder feature while unlicensed. | |
| virtual StatusSignal< bool > & | GetStickyFault_UsingFusedCANcoderWhileUnlicensed (bool refresh=true)=0 |
| Using Fused CANcoder feature while unlicensed. | |
| virtual StatusSignal< bool > & | GetFault_StaticBrakeDisabled (bool refresh=true)=0 |
| Static brake was momentarily disabled due to excessive braking current while disabled. | |
| virtual StatusSignal< bool > & | GetStickyFault_StaticBrakeDisabled (bool refresh=true)=0 |
| Static brake was momentarily disabled due to excessive braking current while disabled. | |
| virtual StatusSignal< double > & | GetClosedLoopProportionalOutput (bool refresh=true)=0 |
| Closed loop proportional component. | |
| virtual StatusSignal< double > & | GetClosedLoopIntegratedOutput (bool refresh=true)=0 |
| Closed loop integrated component. | |
| virtual StatusSignal< double > & | GetClosedLoopFeedForward (bool refresh=true)=0 |
| Feedforward passed by the user. | |
| virtual StatusSignal< double > & | GetClosedLoopDerivativeOutput (bool refresh=true)=0 |
| Closed loop derivative component. | |
| virtual StatusSignal< double > & | GetClosedLoopOutput (bool refresh=true)=0 |
| Closed loop total output. | |
| virtual StatusSignal< double > & | GetClosedLoopReference (bool refresh=true)=0 |
| Value that the closed loop is targeting. | |
| virtual StatusSignal< double > & | GetClosedLoopReferenceSlope (bool refresh=true)=0 |
| Derivative of the target that the closed loop is targeting. | |
| virtual StatusSignal< double > & | GetClosedLoopError (bool refresh=true)=0 |
| The difference between target reference and current measurement. | |
| virtual StatusSignal< double > & | GetDifferentialOutput (bool refresh=true)=0 |
| The calculated motor output for differential followers. | |
| virtual StatusSignal< double > & | GetDifferentialClosedLoopProportionalOutput (bool refresh=true)=0 |
| Differential closed loop proportional component. | |
| virtual StatusSignal< double > & | GetDifferentialClosedLoopIntegratedOutput (bool refresh=true)=0 |
| Differential closed loop integrated component. | |
| virtual StatusSignal< double > & | GetDifferentialClosedLoopFeedForward (bool refresh=true)=0 |
| Differential Feedforward passed by the user. | |
| virtual StatusSignal< double > & | GetDifferentialClosedLoopDerivativeOutput (bool refresh=true)=0 |
| Differential closed loop derivative component. | |
| virtual StatusSignal< double > & | GetDifferentialClosedLoopOutput (bool refresh=true)=0 |
| Differential closed loop total output. | |
| virtual StatusSignal< double > & | GetDifferentialClosedLoopReference (bool refresh=true)=0 |
| Value that the differential closed loop is targeting. | |
| virtual StatusSignal< double > & | GetDifferentialClosedLoopReferenceSlope (bool refresh=true)=0 |
| Derivative of the target that the differential closed loop is targeting. | |
| virtual StatusSignal< double > & | GetDifferentialClosedLoopError (bool refresh=true)=0 |
| The difference between target differential reference and current measurement. | |
| virtual ctre::phoenix::StatusCode | SetPosition (units::angle::turn_t newValue, units::time::second_t timeoutSeconds)=0 |
| Sets the mechanism position of the device in mechanism rotations. | |
| virtual ctre::phoenix::StatusCode | SetPosition (units::angle::turn_t newValue)=0 |
| Sets the mechanism position of the device in mechanism rotations. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFaults (units::time::second_t timeoutSeconds)=0 |
| Clear the sticky faults in the device. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFaults ()=0 |
| Clear the sticky faults in the device. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_Hardware (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Hardware fault occurred. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_Hardware ()=0 |
| Clear sticky fault: Hardware fault occurred. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ProcTemp (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Processor temperature exceeded limit. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ProcTemp ()=0 |
| Clear sticky fault: Processor temperature exceeded limit. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_DeviceTemp (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Device temperature exceeded limit. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_DeviceTemp ()=0 |
| Clear sticky fault: Device temperature exceeded limit. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_Undervoltage (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Device supply voltage dropped to near brownout levels. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_Undervoltage ()=0 |
| Clear sticky fault: Device supply voltage dropped to near brownout levels. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_BootDuringEnable (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Device boot while detecting the enable signal. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_BootDuringEnable ()=0 |
| Clear sticky fault: Device boot while detecting the enable signal. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_UnlicensedFeatureInUse (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: An unlicensed feature is in use, device may not behave as expected. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_UnlicensedFeatureInUse ()=0 |
| Clear sticky fault: An unlicensed feature is in use, device may not behave as expected. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_BridgeBrownout (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Bridge was disabled most likely due to supply voltage dropping too low. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_BridgeBrownout ()=0 |
| Clear sticky fault: Bridge was disabled most likely due to supply voltage dropping too low. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RemoteSensorReset (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: The remote sensor has reset. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RemoteSensorReset ()=0 |
| Clear sticky fault: The remote sensor has reset. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_MissingDifferentialFX (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: The remote Talon used for differential control is not present on CAN Bus. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_MissingDifferentialFX ()=0 |
| Clear sticky fault: The remote Talon used for differential control is not present on CAN Bus. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RemoteSensorPosOverflow (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: The remote sensor position has overflowed. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RemoteSensorPosOverflow ()=0 |
| Clear sticky fault: The remote sensor position has overflowed. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_OverSupplyV (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Supply Voltage has exceeded the maximum voltage rating of device. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_OverSupplyV ()=0 |
| Clear sticky fault: Supply Voltage has exceeded the maximum voltage rating of device. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_UnstableSupplyV (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Supply Voltage is unstable. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_UnstableSupplyV ()=0 |
| Clear sticky fault: Supply Voltage is unstable. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ReverseHardLimit (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Reverse limit switch has been asserted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ReverseHardLimit ()=0 |
| Clear sticky fault: Reverse limit switch has been asserted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ForwardHardLimit (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Forward limit switch has been asserted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ForwardHardLimit ()=0 |
| Clear sticky fault: Forward limit switch has been asserted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ReverseSoftLimit (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Reverse soft limit has been asserted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ReverseSoftLimit ()=0 |
| Clear sticky fault: Reverse soft limit has been asserted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ForwardSoftLimit (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Forward soft limit has been asserted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_ForwardSoftLimit ()=0 |
| Clear sticky fault: Forward soft limit has been asserted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_MissingSoftLimitRemote (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: The remote soft limit device is not present on CAN Bus. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_MissingSoftLimitRemote ()=0 |
| Clear sticky fault: The remote soft limit device is not present on CAN Bus. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_MissingHardLimitRemote (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: The remote limit switch device is not present on CAN Bus. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_MissingHardLimitRemote ()=0 |
| Clear sticky fault: The remote limit switch device is not present on CAN Bus. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RemoteSensorDataInvalid (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: The remote sensor's data is no longer trusted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RemoteSensorDataInvalid ()=0 |
| Clear sticky fault: The remote sensor's data is no longer trusted. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_FusedSensorOutOfSync (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: The remote sensor used for fusion has fallen out of sync to the local sensor. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_FusedSensorOutOfSync ()=0 |
| Clear sticky fault: The remote sensor used for fusion has fallen out of sync to the local sensor. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_StatorCurrLimit (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Stator current limit occured. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_StatorCurrLimit ()=0 |
| Clear sticky fault: Stator current limit occured. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_SupplyCurrLimit (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Supply current limit occured. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_SupplyCurrLimit ()=0 |
| Clear sticky fault: Supply current limit occured. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_UsingFusedCANcoderWhileUnlicensed (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Using Fused CANcoder feature while unlicensed. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_UsingFusedCANcoderWhileUnlicensed ()=0 |
| Clear sticky fault: Using Fused CANcoder feature while unlicensed. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_StaticBrakeDisabled (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Static brake was momentarily disabled due to excessive braking current while disabled. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_StaticBrakeDisabled ()=0 |
| Clear sticky fault: Static brake was momentarily disabled due to excessive braking current while disabled. | |
| Public Member Functions inherited from ctre::phoenix6::hardware::traits::SupportsFOC | |
| virtual | ~SupportsFOC ()=default |
| virtual StatusSignal< bool > & | GetFault_RotorFault1 (bool refresh=true)=0 |
| Trips if a major mechanical or ESD event caused a brief loss of position data triggering a recovery while not in motion. | |
| virtual StatusSignal< bool > & | GetStickyFault_RotorFault1 (bool refresh=true)=0 |
| Trips if a major mechanical or ESD event caused a brief loss of position data triggering a recovery while not in motion. | |
| virtual StatusSignal< bool > & | GetFault_RotorFault2 (bool refresh=true)=0 |
| Trips if a major mechanical or ESD event caused a brief loss of position data triggering a recovery while in motion. | |
| virtual StatusSignal< bool > & | GetStickyFault_RotorFault2 (bool refresh=true)=0 |
| Trips if a major mechanical or ESD event caused a brief loss of position data triggering a recovery while in motion. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RotorFault1 (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Trips if a major mechanical or ESD event caused a brief loss of position data triggering a recovery while not in motion. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RotorFault1 ()=0 |
| Clear sticky fault: Trips if a major mechanical or ESD event caused a brief loss of position data triggering a recovery while not in motion. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RotorFault2 (units::time::second_t timeoutSeconds)=0 |
| Clear sticky fault: Trips if a major mechanical or ESD event caused a brief loss of position data triggering a recovery while in motion. | |
| virtual ctre::phoenix::StatusCode | ClearStickyFault_RotorFault2 ()=0 |
| Clear sticky fault: Trips if a major mechanical or ESD event caused a brief loss of position data triggering a recovery while in motion. | |
| Public Member Functions inherited from ctre::phoenix6::hardware::traits::SupportsMusic | |
| virtual | ~SupportsMusic ()=default |
Detailed Description
Contains everything common between Talon motor controllers that support FOC (requires Phoenix Pro).
Constructor & Destructor Documentation
◆ ~CommonTalonWithFOC()
|
virtualdefault |
Member Function Documentation
◆ SetControl() [1/29]
|
virtual |
Differential control with Motion Magic® Expo average target and torque current difference target.
- Diff_MotionMagicExpoTorqueCurrentFOC_Open Parameters:
- AverageRequest: Average MotionMagicExpoTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential TorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [2/29]
|
virtual |
Differential control with Motion Magic® Expo average target and position difference target using torque current control.
- Diff_MotionMagicExpoTorqueCurrentFOC_Position Parameters:
- AverageRequest: Average MotionMagicExpoTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential PositionTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [3/29]
|
virtual |
Differential control with Motion Magic® Expo average target and velocity difference target using torque current control.
- Diff_MotionMagicExpoTorqueCurrentFOC_Velocity Parameters:
- AverageRequest: Average MotionMagicExpoTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential VelocityTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [4/29]
|
virtual |
Differential control with Motion Magic® average target and torque current difference target.
- Diff_MotionMagicTorqueCurrentFOC_Open Parameters:
- AverageRequest: Average MotionMagicTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential TorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [5/29]
|
virtual |
Differential control with Motion Magic® average target and position difference target using torque current control.
- Diff_MotionMagicTorqueCurrentFOC_Position Parameters:
- AverageRequest: Average MotionMagicTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential PositionTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [6/29]
|
virtual |
Differential control with Motion Magic® average target and velocity difference target using torque current control.
- Diff_MotionMagicTorqueCurrentFOC_Velocity Parameters:
- AverageRequest: Average MotionMagicTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential VelocityTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [7/29]
|
virtual |
Differential control with Motion Magic® Velocity average target and torque current difference target.
- Diff_MotionMagicVelocityTorqueCurrentFOC_Open Parameters:
- AverageRequest: Average MotionMagicVelocityTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential TorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [8/29]
|
virtual |
Differential control with Motion Magic® Velocity average target and position difference target using torque current control.
- Diff_MotionMagicVelocityTorqueCurrentFOC_Position Parameters:
- AverageRequest: Average MotionMagicVelocityTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential PositionTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [9/29]
|
virtual |
Differential control with Motion Magic® Velocity average target and velocity difference target using torque current control.
- Diff_MotionMagicVelocityTorqueCurrentFOC_Velocity Parameters:
- AverageRequest: Average MotionMagicVelocityTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential VelocityTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [10/29]
|
virtual |
Differential control with position average target and torque current difference target.
- Diff_PositionTorqueCurrentFOC_Open Parameters:
- AverageRequest: Average PositionTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential TorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [11/29]
|
virtual |
Differential control with position average target and position difference target using torque current control.
- Diff_PositionTorqueCurrentFOC_Position Parameters:
- AverageRequest: Average PositionTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential PositionTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [12/29]
|
virtual |
Differential control with position average target and velocity difference target using torque current control.
- Diff_PositionTorqueCurrentFOC_Velocity Parameters:
- AverageRequest: Average PositionTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential VelocityTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [13/29]
|
virtual |
Differential control with torque current average target and torque current difference target.
- Diff_TorqueCurrentFOC_Open Parameters:
- AverageRequest: Average TorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential TorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [14/29]
|
virtual |
Differential control with torque current average target and position difference target.
- Diff_TorqueCurrentFOC_Position Parameters:
- AverageRequest: Average TorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential PositionTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [15/29]
|
virtual |
Differential control with torque current average target and velocity difference target.
- Diff_TorqueCurrentFOC_Velocity Parameters:
- AverageRequest: Average TorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential VelocityTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [16/29]
|
virtual |
Differential control with velocity average target and torque current difference target.
- Diff_VelocityTorqueCurrentFOC_Open Parameters:
- AverageRequest: Average VelocityTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential TorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [17/29]
|
virtual |
Differential control with velocity average target and position difference target using torque current control.
- Diff_VelocityTorqueCurrentFOC_Position Parameters:
- AverageRequest: Average VelocityTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential PositionTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [18/29]
|
virtual |
Differential control with velocity average target and velocity difference target using torque current control.
- Diff_VelocityTorqueCurrentFOC_Velocity Parameters:
- AverageRequest: Average VelocityTorqueCurrentFOC request of the mechanism.
- DifferentialRequest: Differential VelocityTorqueCurrentFOC request of the mechanism.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [19/29]
|
virtual |
Control device with generic control request object.
User must make sure the specified object is castable to a valid control request, otherwise this function will fail at run-time and return the NotSupported StatusCode
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Reimplemented from ctre::phoenix6::hardware::traits::CommonTalon.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [20/29]
|
virtual |
Requests Motion Magic® Expo to target a final position using an exponential motion profile.
This dynamic request allows runtime changes to the profile kV, kA, and (optional) Cruise Velocity. Users can optionally provide a torque current feedforward.
Motion Magic® Expo produces a motion profile in real-time while attempting to honor the specified Cruise Velocity (optional) and the mechanism kV and kA. Note that unlike the slot gains, the Expo_kV and Expo_kA parameters are always in output units of Volts.
Setting the Cruise Velocity to 0 will allow the profile to run to the max possible velocity based on Expo_kV. This control mode does not use the Acceleration or Jerk configs.
Target position can be changed on-the-fly and Motion Magic® will do its best to adjust the profile. This control mode is based on torque current, so relevant closed-loop gains will use Amperes for the numerator.
- DynamicMotionMagicExpoTorqueCurrentFOC Parameters:
- Position: Position to drive toward in rotations.
kV: Mechanism kV for profiling. Unlike the kV slot gain, this is always in units of V/rps.
This represents the amount of voltage necessary to hold a velocity. In terms of the Motion Magic® Expo profile, a higher kV results in a slower maximum velocity.
kA: Mechanism kA for profiling. Unlike the kA slot gain, this is always in units of V/rps².
This represents the amount of voltage necessary to achieve an acceleration. In terms of the Motion Magic® Expo profile, a higher kA results in a slower acceleration.
- Velocity: Cruise velocity for profiling. The signage does not matter as the device will use the absolute value for profile generation. Setting this to 0 will allow the profile to run to the max possible velocity based on Expo_kV.
FeedForward: Feedforward to apply in torque current in Amperes. This is added to the output of the onboard feedforward terms.
User can use motor's kT to scale Newton-meter to Amperes.
- Slot: Select which gains are applied by selecting the slot. Use the configuration api to set the gain values for the selected slot before enabling this feature. Slot must be within [0,2].
- OverrideCoastDurNeutral: Set to true to coast the rotor when output is zero (or within deadband). Set to false to use the NeutralMode configuration setting (default). This flag exists to provide the fundamental behavior of this control when output is zero, which is to provide 0A (zero torque).
- LimitForwardMotion: Set to true to force forward limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
- LimitReverseMotion: Set to true to force reverse limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
IgnoreHardwareLimits: Set to true to ignore hardware limit switches and the LimitForwardMotion and LimitReverseMotion parameters, instead allowing motion.
This can be useful on mechanisms such as an intake/feeder, where a limit switch stops motion while intaking but should be ignored when feeding to a shooter.
The hardware limit faults and Forward/ReverseLimit signals will still report the values of the limit switches regardless of this parameter.
IgnoreSoftwareLimits: Set to true to ignore software limits, instead allowing motion.
This can be useful when calibrating the zero point of a mechanism such as an elevator.
The software limit faults will still report the values of the software limits regardless of this parameter.
UseTimesync: Set to true to delay applying this control request until a timesync boundary (requires Phoenix Pro and CANivore). This eliminates the impact of nondeterministic network delays in exchange for a larger but deterministic control latency.
This requires setting the ControlTimesyncFreqHz config in MotorOutputConfigs. Additionally, when this is enabled, the UpdateFreqHz of this request should be set to 0 Hz.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [21/29]
|
virtual |
Requests Motion Magic® to target a final position using a motion profile.
This dynamic request allows runtime changes to Cruise Velocity, Acceleration, and (optional) Jerk. Users can optionally provide a torque current feedforward.
Motion Magic® produces a motion profile in real-time while attempting to honor the specified Cruise Velocity, Acceleration, and (optional) Jerk. This control mode does not use the Expo_kV or Expo_kA configs.
Target position can be changed on-the-fly and Motion Magic® will do its best to adjust the profile. This control mode is based on torque current, so relevant closed-loop gains will use Amperes for the numerator.
- DynamicMotionMagicTorqueCurrentFOC Parameters:
- Position: Position to drive toward in rotations.
- Velocity: Cruise velocity for profiling. The signage does not matter as the device will use the absolute value for profile generation.
- Acceleration: Acceleration for profiling. The signage does not matter as the device will use the absolute value for profile generation.
Jerk: Jerk for profiling. The signage does not matter as the device will use the absolute value for profile generation.
Jerk is optional; if this is set to zero, then Motion Magic® will not apply a Jerk limit.
FeedForward: Feedforward to apply in torque current in Amperes. This is added to the output of the onboard feedforward terms.
User can use motor's kT to scale Newton-meter to Amperes.
- Slot: Select which gains are applied by selecting the slot. Use the configuration api to set the gain values for the selected slot before enabling this feature. Slot must be within [0,2].
- OverrideCoastDurNeutral: Set to true to coast the rotor when output is zero (or within deadband). Set to false to use the NeutralMode configuration setting (default). This flag exists to provide the fundamental behavior of this control when output is zero, which is to provide 0A (zero torque).
- LimitForwardMotion: Set to true to force forward limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
- LimitReverseMotion: Set to true to force reverse limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
IgnoreHardwareLimits: Set to true to ignore hardware limit switches and the LimitForwardMotion and LimitReverseMotion parameters, instead allowing motion.
This can be useful on mechanisms such as an intake/feeder, where a limit switch stops motion while intaking but should be ignored when feeding to a shooter.
The hardware limit faults and Forward/ReverseLimit signals will still report the values of the limit switches regardless of this parameter.
IgnoreSoftwareLimits: Set to true to ignore software limits, instead allowing motion.
This can be useful when calibrating the zero point of a mechanism such as an elevator.
The software limit faults will still report the values of the software limits regardless of this parameter.
UseTimesync: Set to true to delay applying this control request until a timesync boundary (requires Phoenix Pro and CANivore). This eliminates the impact of nondeterministic network delays in exchange for a larger but deterministic control latency.
This requires setting the ControlTimesyncFreqHz config in MotorOutputConfigs. Additionally, when this is enabled, the UpdateFreqHz of this request should be set to 0 Hz.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [22/29]
|
virtual |
Apply a generic empty control used to do nothing.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Reimplemented from ctre::phoenix6::hardware::traits::CommonTalon.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [23/29]
|
virtual |
Requests Motion Magic® to target a final position using an exponential motion profile.
Users can optionally provide a torque current feedforward.
Motion Magic® Expo produces a motion profile in real-time while attempting to honor the Cruise Velocity (optional) and the mechanism kV and kA, specified via the Motion Magic® configuration values. Note that unlike the slot gains, the Expo_kV and Expo_kA configs are always in output units of Volts.
Setting Cruise Velocity to 0 will allow the profile to run to the max possible velocity based on Expo_kV. This control mode does not use the Acceleration or Jerk configs.
Target position can be changed on-the-fly and Motion Magic® will do its best to adjust the profile. This control mode is based on torque current, so relevant closed-loop gains will use Amperes for the numerator.
- MotionMagicExpoTorqueCurrentFOC Parameters:
- Position: Position to drive toward in rotations.
FeedForward: Feedforward to apply in torque current in Amperes. This is added to the output of the onboard feedforward terms.
User can use motor's kT to scale Newton-meter to Amperes.
- Slot: Select which gains are applied by selecting the slot. Use the configuration api to set the gain values for the selected slot before enabling this feature. Slot must be within [0,2].
- OverrideCoastDurNeutral: Set to true to coast the rotor when output is zero (or within deadband). Set to false to use the NeutralMode configuration setting (default). This flag exists to provide the fundamental behavior of this control when output is zero, which is to provide 0A (zero torque).
- LimitForwardMotion: Set to true to force forward limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
- LimitReverseMotion: Set to true to force reverse limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
IgnoreHardwareLimits: Set to true to ignore hardware limit switches and the LimitForwardMotion and LimitReverseMotion parameters, instead allowing motion.
This can be useful on mechanisms such as an intake/feeder, where a limit switch stops motion while intaking but should be ignored when feeding to a shooter.
The hardware limit faults and Forward/ReverseLimit signals will still report the values of the limit switches regardless of this parameter.
IgnoreSoftwareLimits: Set to true to ignore software limits, instead allowing motion.
This can be useful when calibrating the zero point of a mechanism such as an elevator.
The software limit faults will still report the values of the software limits regardless of this parameter.
UseTimesync: Set to true to delay applying this control request until a timesync boundary (requires Phoenix Pro and CANivore). This eliminates the impact of nondeterministic network delays in exchange for a larger but deterministic control latency.
This requires setting the ControlTimesyncFreqHz config in MotorOutputConfigs. Additionally, when this is enabled, the UpdateFreqHz of this request should be set to 0 Hz.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [24/29]
|
virtual |
Requests Motion Magic® to target a final position using a motion profile.
Users can optionally provide a torque current feedforward.
Motion Magic® produces a motion profile in real-time while attempting to honor the Cruise Velocity, Acceleration, and (optional) Jerk specified via the Motion Magic® configuration values. This control mode does not use the Expo_kV or Expo_kA configs.
Target position can be changed on-the-fly and Motion Magic® will do its best to adjust the profile. This control mode is based on torque current, so relevant closed-loop gains will use Amperes for the numerator.
- MotionMagicTorqueCurrentFOC Parameters:
- Position: Position to drive toward in rotations.
FeedForward: Feedforward to apply in torque current in Amperes. This is added to the output of the onboard feedforward terms.
User can use motor's kT to scale Newton-meter to Amperes.
- Slot: Select which gains are applied by selecting the slot. Use the configuration api to set the gain values for the selected slot before enabling this feature. Slot must be within [0,2].
- OverrideCoastDurNeutral: Set to true to coast the rotor when output is zero (or within deadband). Set to false to use the NeutralMode configuration setting (default). This flag exists to provide the fundamental behavior of this control when output is zero, which is to provide 0A (zero torque).
- LimitForwardMotion: Set to true to force forward limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
- LimitReverseMotion: Set to true to force reverse limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
IgnoreHardwareLimits: Set to true to ignore hardware limit switches and the LimitForwardMotion and LimitReverseMotion parameters, instead allowing motion.
This can be useful on mechanisms such as an intake/feeder, where a limit switch stops motion while intaking but should be ignored when feeding to a shooter.
The hardware limit faults and Forward/ReverseLimit signals will still report the values of the limit switches regardless of this parameter.
IgnoreSoftwareLimits: Set to true to ignore software limits, instead allowing motion.
This can be useful when calibrating the zero point of a mechanism such as an elevator.
The software limit faults will still report the values of the software limits regardless of this parameter.
UseTimesync: Set to true to delay applying this control request until a timesync boundary (requires Phoenix Pro and CANivore). This eliminates the impact of nondeterministic network delays in exchange for a larger but deterministic control latency.
This requires setting the ControlTimesyncFreqHz config in MotorOutputConfigs. Additionally, when this is enabled, the UpdateFreqHz of this request should be set to 0 Hz.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [25/29]
|
virtual |
Requests Motion Magic® to target a final velocity using a motion profile.
This allows smooth transitions between velocity set points. Users can optionally provide a torque feedforward.
Motion Magic® Velocity produces a motion profile in real-time while attempting to honor the specified Acceleration and (optional) Jerk. This control mode does not use the CruiseVelocity, Expo_kV, or Expo_kA configs.
If the specified acceleration is zero, the Acceleration under Motion Magic® configuration parameter is used instead. This allows for runtime adjustment of acceleration for advanced users. Jerk is also specified in the Motion Magic® persistent configuration values. If Jerk is set to zero, Motion Magic® will produce a trapezoidal acceleration profile.
Target velocity can also be changed on-the-fly and Motion Magic® will do its best to adjust the profile. This control mode is based on torque current, so relevant closed-loop gains will use Amperes for the numerator.
- MotionMagicVelocityTorqueCurrentFOC Parameters:
- Velocity: Target velocity to drive toward in rotations per second. This can be changed on-the fly.
- Acceleration: This is the absolute Acceleration to use generating the profile. If this parameter is zero, the Acceleration persistent configuration parameter is used instead. Acceleration is in rotations per second squared. If nonzero, the signage does not matter as the absolute value is used.
FeedForward: Feedforward to apply in torque current in Amperes. This is added to the output of the onboard feedforward terms.
User can use motor's kT to scale Newton-meter to Amperes.
- Slot: Select which gains are applied by selecting the slot. Use the configuration api to set the gain values for the selected slot before enabling this feature. Slot must be within [0,2].
- OverrideCoastDurNeutral: Set to true to coast the rotor when output is zero (or within deadband). Set to false to use the NeutralMode configuration setting (default). This flag exists to provide the fundamental behavior of this control when output is zero, which is to provide 0A (zero torque).
- LimitForwardMotion: Set to true to force forward limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
- LimitReverseMotion: Set to true to force reverse limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
IgnoreHardwareLimits: Set to true to ignore hardware limit switches and the LimitForwardMotion and LimitReverseMotion parameters, instead allowing motion.
This can be useful on mechanisms such as an intake/feeder, where a limit switch stops motion while intaking but should be ignored when feeding to a shooter.
The hardware limit faults and Forward/ReverseLimit signals will still report the values of the limit switches regardless of this parameter.
IgnoreSoftwareLimits: Set to true to ignore software limits, instead allowing motion.
This can be useful when calibrating the zero point of a mechanism such as an elevator.
The software limit faults will still report the values of the software limits regardless of this parameter.
UseTimesync: Set to true to delay applying this control request until a timesync boundary (requires Phoenix Pro and CANivore). This eliminates the impact of nondeterministic network delays in exchange for a larger but deterministic control latency.
This requires setting the ControlTimesyncFreqHz config in MotorOutputConfigs. Additionally, when this is enabled, the UpdateFreqHz of this request should be set to 0 Hz.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [26/29]
|
virtual |
Plays a single tone at the user specified frequency.
- MusicTone Parameters:
- AudioFrequency: Sound frequency to play. A value of zero will silence the device. The effective frequency range is 10-20000 Hz. Any nonzero frequency less than 10 Hz will be capped to 10 Hz. Any frequency above 20 kHz will be capped to 20 kHz.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsMusic.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [27/29]
|
virtual |
Request PID to target position with torque current feedforward.
This control mode will set the motor's position setpoint to the position specified by the user. In addition, it will apply an additional torque current as an arbitrary feedforward value.
- PositionTorqueCurrentFOC Parameters:
- Position: Position to drive toward in rotations.
- Velocity: Velocity to drive toward in rotations per second. This is typically used for motion profiles generated by the robot program.
FeedForward: Feedforward to apply in torque current in Amperes. This is added to the output of the onboard feedforward terms.
User can use motor's kT to scale Newton-meter to Amperes.
- Slot: Select which gains are applied by selecting the slot. Use the configuration api to set the gain values for the selected slot before enabling this feature. Slot must be within [0,2].
- OverrideCoastDurNeutral: Set to true to coast the rotor when output is zero (or within deadband). Set to false to use the NeutralMode configuration setting (default). This flag exists to provide the fundamental behavior of this control when output is zero, which is to provide 0A (zero torque).
- LimitForwardMotion: Set to true to force forward limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
- LimitReverseMotion: Set to true to force reverse limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
IgnoreHardwareLimits: Set to true to ignore hardware limit switches and the LimitForwardMotion and LimitReverseMotion parameters, instead allowing motion.
This can be useful on mechanisms such as an intake/feeder, where a limit switch stops motion while intaking but should be ignored when feeding to a shooter.
The hardware limit faults and Forward/ReverseLimit signals will still report the values of the limit switches regardless of this parameter.
IgnoreSoftwareLimits: Set to true to ignore software limits, instead allowing motion.
This can be useful when calibrating the zero point of a mechanism such as an elevator.
The software limit faults will still report the values of the software limits regardless of this parameter.
UseTimesync: Set to true to delay applying this control request until a timesync boundary (requires Phoenix Pro and CANivore). This eliminates the impact of nondeterministic network delays in exchange for a larger but deterministic control latency.
This requires setting the ControlTimesyncFreqHz config in MotorOutputConfigs. Additionally, when this is enabled, the UpdateFreqHz of this request should be set to 0 Hz.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [28/29]
|
virtual |
Request a specified motor current (field oriented control).
This control request will drive the motor to the requested motor (stator) current value. This leverages field oriented control (FOC), which means greater peak power than what is documented. This scales to torque based on Motor's kT constant.
- TorqueCurrentFOC Parameters:
- Output: Amount of motor current in Amperes
- MaxAbsDutyCycle: The maximum absolute motor output that can be applied, which effectively limits the velocity. For example, 0.50 means no more than 50% output in either direction. This is useful for preventing the motor from spinning to its terminal velocity when there is no external torque applied unto the rotor. Note this is absolute maximum, so the value should be between zero and one.
- Deadband: Deadband in Amperes. If torque request is within deadband, the bridge output is neutral. If deadband is set to zero then there is effectively no deadband. Note if deadband is zero, a free spinning motor will spin for quite a while as the firmware attempts to hold the motor's bemf. If user expects motor to cease spinning quickly with a demand of zero, we recommend a deadband of one Ampere. This value will be converted to an integral value of amps.
- OverrideCoastDurNeutral: Set to true to coast the rotor when output is zero (or within deadband). Set to false to use the NeutralMode configuration setting (default). This flag exists to provide the fundamental behavior of this control when output is zero, which is to provide 0A (zero torque).
- LimitForwardMotion: Set to true to force forward limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
- LimitReverseMotion: Set to true to force reverse limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
IgnoreHardwareLimits: Set to true to ignore hardware limit switches and the LimitForwardMotion and LimitReverseMotion parameters, instead allowing motion.
This can be useful on mechanisms such as an intake/feeder, where a limit switch stops motion while intaking but should be ignored when feeding to a shooter.
The hardware limit faults and Forward/ReverseLimit signals will still report the values of the limit switches regardless of this parameter.
IgnoreSoftwareLimits: Set to true to ignore software limits, instead allowing motion.
This can be useful when calibrating the zero point of a mechanism such as an elevator.
The software limit faults will still report the values of the software limits regardless of this parameter.
UseTimesync: Set to true to delay applying this control request until a timesync boundary (requires Phoenix Pro and CANivore). This eliminates the impact of nondeterministic network delays in exchange for a larger but deterministic control latency.
This requires setting the ControlTimesyncFreqHz config in MotorOutputConfigs. Additionally, when this is enabled, the UpdateFreqHz of this request should be set to 0 Hz.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
◆ SetControl() [29/29]
|
virtual |
Request PID to target velocity with torque current feedforward.
This control mode will set the motor's velocity setpoint to the velocity specified by the user. In addition, it will apply an additional torque current as an arbitrary feedforward value.
- VelocityTorqueCurrentFOC Parameters:
- Velocity: Velocity to drive toward in rotations per second.
- Acceleration: Acceleration to drive toward in rotations per second squared. This is typically used for motion profiles generated by the robot program.
FeedForward: Feedforward to apply in torque current in Amperes. This is added to the output of the onboard feedforward terms.
User can use motor's kT to scale Newton-meter to Amperes.
- Slot: Select which gains are applied by selecting the slot. Use the configuration api to set the gain values for the selected slot before enabling this feature. Slot must be within [0,2].
- OverrideCoastDurNeutral: Set to true to coast the rotor when output is zero (or within deadband). Set to false to use the NeutralMode configuration setting (default). This flag exists to provide the fundamental behavior of this control when output is zero, which is to provide 0A (zero torque).
- LimitForwardMotion: Set to true to force forward limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
- LimitReverseMotion: Set to true to force reverse limiting. This allows users to use other limit switch sensors connected to robot controller. This also allows use of active sensors that require external power.
IgnoreHardwareLimits: Set to true to ignore hardware limit switches and the LimitForwardMotion and LimitReverseMotion parameters, instead allowing motion.
This can be useful on mechanisms such as an intake/feeder, where a limit switch stops motion while intaking but should be ignored when feeding to a shooter.
The hardware limit faults and Forward/ReverseLimit signals will still report the values of the limit switches regardless of this parameter.
IgnoreSoftwareLimits: Set to true to ignore software limits, instead allowing motion.
This can be useful when calibrating the zero point of a mechanism such as an elevator.
The software limit faults will still report the values of the software limits regardless of this parameter.
UseTimesync: Set to true to delay applying this control request until a timesync boundary (requires Phoenix Pro and CANivore). This eliminates the impact of nondeterministic network delays in exchange for a larger but deterministic control latency.
This requires setting the ControlTimesyncFreqHz config in MotorOutputConfigs. Additionally, when this is enabled, the UpdateFreqHz of this request should be set to 0 Hz.
- Parameters
-
request Control object to request of the device
- Returns
- Status code of the request
Implements ctre::phoenix6::hardware::traits::SupportsFOC.
Reimplemented in ctre::phoenix6::hardware::core::CoreTalonFX.
The documentation for this class was generated from the following file:
- ctre/phoenix6/hardware/traits/CommonTalonWithFOC.hpp
