Sets the swerve drive module states to point inward on the robot in an "X" fashion, creating a natural brake which will oppose any motion. More...
#include <ctre/phoenix6/swerve/SwerveRequest.hpp>
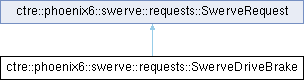
Public Member Functions | |
| ctre::phoenix::StatusCode | Apply (SwerveRequest::ControlParameters const ¶meters, std::span< std::unique_ptr< impl::SwerveModuleImpl > const > modulesToApply) override |
| Applies this swerve request to the given modules. | |
| SwerveDriveBrake & | WithDriveRequestType (impl::DriveRequestType newDriveRequestType) & |
| Modifies the DriveRequestType parameter and returns itself. | |
| SwerveDriveBrake && | WithDriveRequestType (impl::DriveRequestType newDriveRequestType) && |
| Modifies the DriveRequestType parameter and returns itself. | |
| SwerveDriveBrake & | WithSteerRequestType (impl::SteerRequestType newSteerRequestType) & |
| Modifies the SteerRequestType parameter and returns itself. | |
| SwerveDriveBrake && | WithSteerRequestType (impl::SteerRequestType newSteerRequestType) && |
| Modifies the SteerRequestType parameter and returns itself. | |
 Public Member Functions inherited from ctre::phoenix6::swerve::requests::SwerveRequest | |
| virtual | ~SwerveRequest ()=default |
Public Attributes | |
| impl::DriveRequestType | DriveRequestType = impl::DriveRequestType::OpenLoopVoltage |
| The type of control request to use for the drive motor. | |
| impl::SteerRequestType | SteerRequestType = impl::SteerRequestType::Position |
| The type of control request to use for the steer motor. | |
Additional Inherited Members | |
| Public Types inherited from ctre::phoenix6::swerve::requests::SwerveRequest | |
| using | ControlParameters = impl::SwerveDrivetrainImpl::ControlParameters |
Detailed Description
Sets the swerve drive module states to point inward on the robot in an "X" fashion, creating a natural brake which will oppose any motion.
Member Function Documentation
◆ Apply()
|
inlineoverridevirtual |
Applies this swerve request to the given modules.
This is typically called by the SwerveDrivetrain.
- Parameters
-
parameters Parameters the control request needs to calculate the module state modulesToApply Modules to which the control request is applied
- Returns
- Status code of sending the request
Implements ctre::phoenix6::swerve::requests::SwerveRequest.
◆ WithDriveRequestType() [1/2]
|
inline |
Modifies the DriveRequestType parameter and returns itself.
The type of control request to use for the drive motor.
- Parameters
-
newDriveRequestType Parameter to modify
- Returns
- this object
◆ WithDriveRequestType() [2/2]
|
inline |
Modifies the DriveRequestType parameter and returns itself.
The type of control request to use for the drive motor.
- Parameters
-
newDriveRequestType Parameter to modify
- Returns
- this object
◆ WithSteerRequestType() [1/2]
|
inline |
Modifies the SteerRequestType parameter and returns itself.
The type of control request to use for the steer motor.
- Parameters
-
newSteerRequestType Parameter to modify
- Returns
- this object
◆ WithSteerRequestType() [2/2]
|
inline |
Modifies the SteerRequestType parameter and returns itself.
The type of control request to use for the steer motor.
- Parameters
-
newSteerRequestType Parameter to modify
- Returns
- this object
Member Data Documentation
◆ DriveRequestType
| impl::DriveRequestType ctre::phoenix6::swerve::requests::SwerveDriveBrake::DriveRequestType = impl::DriveRequestType::OpenLoopVoltage |
The type of control request to use for the drive motor.
◆ SteerRequestType
| impl::SteerRequestType ctre::phoenix6::swerve::requests::SwerveDriveBrake::SteerRequestType = impl::SteerRequestType::Position |
The type of control request to use for the steer motor.
The documentation for this class was generated from the following file:
- ctre/phoenix6/swerve/SwerveRequest.hpp